

Modern intelligent systems rely heavily on accurate environmental perception. Whether it’s an autonomous vehicle detecting pedestrians, an industrial robot navigating factory floors, or a smart drone maintaining stable flight, the ability to interpret surroundings reliably is critical. However, no single sensor can provide perfect information under all conditions.
This is where sensor fusion becomes essential. Sensor fusion combines data from multiple sensors to create a more accurate, reliable, and complete understanding of the environment. In modern embedded platforms, it has become the backbone of advanced perception pipelines. From automotive ADAS to robotics and IoT systems, sensor fusion is redefining the future of intelligent devices.
In this blog, we’ll explore how sensor fusion works, why it matters in embedded systems, and the key challenges involved in building dependable perception architectures.
What is Sensor Fusion?
Sensor fusion refers to the process of integrating information from multiple sensors to improve decision-making and system awareness.
For example, in an autonomous vehicle:
- Cameras provide visual recognition
- LiDAR measures distance and object shape
- Radar performs well in poor weather
- Ultrasonic sensors detect nearby obstacles
Individually, each sensor has limitations. Together, they create a far more dependable perception model.
This collaborative approach is becoming a critical component of modern embedded system design, especially in safety-critical industries.
Why Single Sensors Are Not Enough
Every sensor operates differently and comes with unique weaknesses.
Cameras
- Excellent object recognition
- Struggle in low light or fog
LiDAR
- High spatial accuracy
- Expensive and sensitive to environmental conditions
Radar
- Performs well in rain and darkness
- Lower resolution than cameras
Ultrasonic Sensors
- Ideal for close-range detection
- Limited operating range
Sensor fusion minimizes these weaknesses by combining complementary sensor data into one unified output.
This balance between reliability and efficiency is central to advanced embedded designing practices.
Components of a Sensor Fusion Pipeline
A reliable perception pipeline typically includes several stages:
1. Data Acquisition
Raw data is collected from various sensors in real time.
2. Sensor Synchronization
Data streams are time-aligned to ensure accurate interpretation.
3. Data Preprocessing
Noise filtering, calibration, and normalization improve data quality.
4. Fusion Algorithms
The system combines sensor inputs using advanced algorithms.
5. Object Detection and Tracking
The fused data is used to identify and monitor objects dynamically.
6. Decision-Making
The perception engine sends processed information to control systems.
Efficient pipeline management requires strong expertise in embedded system design, particularly for low-latency applications.
Common Sensor Fusion Techniques
Different applications use different fusion methods depending on performance and complexity requirements.
Kalman Filters
Widely used for estimating object position and motion in dynamic systems.
Extended Kalman Filters (EKF)
Suitable for nonlinear systems like autonomous navigation.
Particle Filters
Helpful in highly uncertain environments.
Deep Learning-Based Fusion
AI models combine sensor inputs for advanced perception tasks.
Bayesian Fusion
Uses probabilistic reasoning to improve decision accuracy.
Modern embedded platforms increasingly integrate AI-driven fusion approaches for enhanced perception capabilities.
Sensor Fusion in Automotive Embedded Systems
Automotive systems are among the biggest adopters of sensor fusion technology.
ADAS and autonomous driving platforms rely on fused perception to support:
- Lane detection
- Adaptive cruise control
- Pedestrian detection
- Collision avoidance
- Driver monitoring
For example, if a camera fails to identify an object in heavy rain, radar can still provide distance and speed information. This redundancy improves safety and reliability significantly.
As software-defined vehicles evolve, automotive manufacturers are working closely with specialized embedded system company partners to develop scalable perception architectures.
Key Challenges in Building Reliable Perception Pipelines
Although sensor fusion improves accuracy, implementing it in embedded systems is far from simple.
1. Real-Time Processing Requirements
Perception systems must process enormous amounts of sensor data with minimal latency.
2. Computational Constraints
Embedded systems often operate within strict power and hardware limitations.
3. Sensor Calibration
Misaligned sensors can generate incorrect outputs, reducing reliability.
4. Environmental Variability
Rain, fog, glare, and vibration can impact sensor performance.
5. Functional Safety Compliance
Safety-critical applications must meet standards like ISO 26262.
6. Data Bandwidth Management
High-resolution sensors generate massive data streams that require efficient handling.
Addressing these challenges demands robust embedded design strategies combined with hardware-software optimization.
Role of AI in Sensor Fusion
Artificial Intelligence is transforming sensor fusion capabilities.
AI-driven perception systems can:
- Identify complex objects
- Predict motion patterns
- Improve contextual understanding
- Reduce false detections
Machine learning models also help systems adapt to changing environments over time.
However, deploying AI workloads on embedded hardware requires careful optimization to balance:
- Performance
- Power consumption
- Thermal efficiency
- Real-time responsiveness
This is where modern embedded system company expertise becomes especially valuable.
Edge Computing and Sensor Fusion
Sensor fusion increasingly happens at the edge rather than in the cloud.
Why? Because perception systems require immediate decision-making.
Edge-based processing offers:
- Lower latency
- Improved reliability
- Reduced network dependency
- Better data privacy
Modern automotive SoCs and AI accelerators are specifically designed to handle real-time sensor fusion workloads directly within embedded devices.
This shift is driving innovation in next-generation embedded system design architectures.
Low-Power SoC Chip Design: Strategies for Mobile and IoT Devices
Future Trends in Sensor Fusion
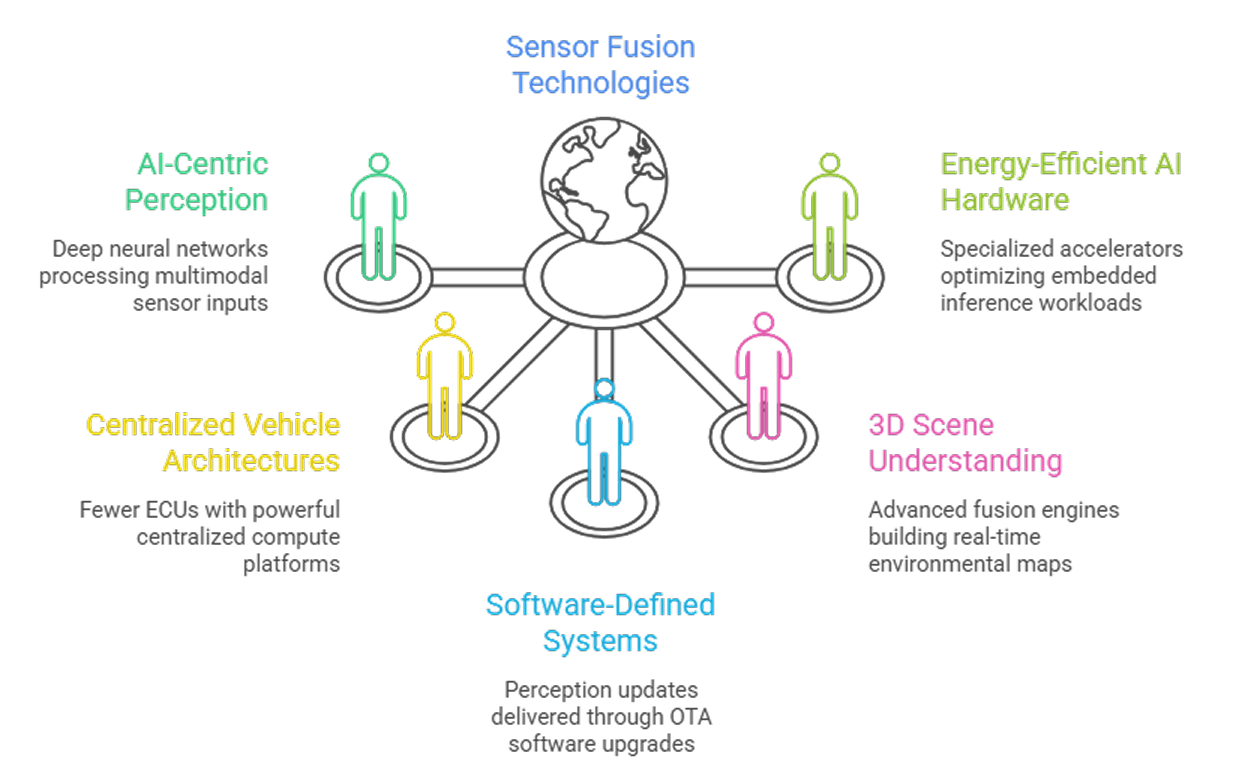
Sensor fusion technologies continue evolving rapidly.
Some emerging trends include:
AI-Centric Perception
Deep neural networks handling multimodal sensor inputs.
Centralized Vehicle Architectures
Fewer ECUs with powerful centralized compute platforms.
Software-Defined Systems
Perception updates delivered through OTA software upgrades.
3D Scene Understanding
Advanced fusion engines building real-time environmental maps.
Energy-Efficient AI Hardware
Specialized accelerators optimizing embedded inference workloads.
As embedded intelligence expands across industries, sensor fusion will remain at the core of reliable perception systems.
Build Smarter Embedded Perception Systems with Tessolve
At Tessolve, we specialize in delivering end-to-end embedded and semiconductor engineering solutions for next-generation intelligent systems. From hardware architecture and AI-enabled perception pipelines to validation, automotive software, and SoC design services, we help businesses accelerate innovation with reliable, scalable solutions. Our expertise spans ADAS, embedded AI, edge computing, sensor integration, and high-performance computing platforms. With deep industry experience and strong engineering capabilities, Tessolve empowers organizations to develop advanced embedded products that meet demanding performance, safety, and quality requirements across automotive, industrial, and connected device ecosystems.
FAQs
1. What is sensor fusion in embedded systems?
Sensor fusion combines data from multiple sensors to improve accuracy, reliability, and environmental understanding in intelligent embedded applications.
2. Why is sensor fusion important for autonomous vehicles?
It helps vehicles detect objects accurately by combining camera, radar, and LiDAR data for safer real-time decision-making in complex environments.
3. Which sensors are commonly used in perception pipelines?
Common sensors include cameras, radar, LiDAR, ultrasonic sensors, GPS modules, and inertial measurement units used for environmental awareness.
4. What challenges exist in implementing sensor fusion?
Major challenges include real-time processing, sensor calibration, power limitations, environmental interference, and maintaining functional safety compliance standards.
5. How does AI improve sensor fusion systems?
AI enhances object detection, motion prediction, contextual understanding, and adaptive learning, making perception systems smarter and more reliable in dynamic conditions.


